My contribution
I contributed across mechanical design, prototyping, fabrication, assembly, drivetrain integration, pneumatics, electronics, and sensors. I also worked on programming-related integration, testing, troubleshooting, maintenance, and redesign between competitions.
Our robots were collaborative team builds. My experience came from connecting subsystems and carrying design decisions through fabrication, integration, and competition.
Mechanisms in detail
The team’s original demonstrations document two different mobile-goal mechanisms: a rear tilter and a two-piston front clamp. Both illustrate the packaging and actuation decisions involved in building a complete competition robot.
Autonomous systems
The team documented an autonomous approach combining odometry, generated x/y path points, and Pure Pursuit motor commands. Reliable robot motion depended on the interaction of sensing, control, and repeatable mechanical behavior.
The 315-point programming-skills demonstration below was explicitly published as an unofficial run. It documents team-level system behavior rather than an official tournament score or individual code authorship.
Early-season development
The November 2019 Tower Takeover driver-skills video documents an earlier version of the team’s cube-handling robot.
Team achievements
-
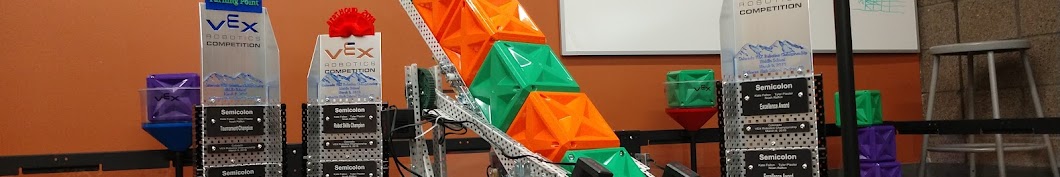
2020 Colorado state tournament champions
-
2021 10th in high-school Robot Skills at Live Remote Worlds
-
2021 WAVE @ WPI tournament champions with alliance partner 169A
Explore the original team channel ↗